The Stop Test
We test whether an AI can run a robot while a person can still stop it, limit it and watch it. Every result goes on GitHub with its sources and its code, so anyone can run it again.
Every test so far runs in simulation or reads public code. We have not run our code on a real robot.
What we found
Five kinds of stop, each tried at 20 moments spread over one full step, under Unitree's own published walking policy. Simulation, 9 November 2026.
20 of 20 upright
0 of 20 upright
0 of 20 upright
0 of 20 upright
0 of 20 upright
Each dot is one run: bright = upright 4 s after the stop, dim = not upright."First touch" = first floor contact by anything but a foot, seconds after the stop.Result and code on GitHub
One G1 simulation model, one crude jump push. Its centre of mass rose 22, 33 or 82 cm, depending on whose published torque limits we loaded: Unitree's motor curves, Unitree's training config, or NVIDIA Isaac Lab's.
Result and code →Unitree's Python SDK waits 1 second for a reply, then reports error 3104. One developer measured a 4.19-second wave on a real G1. By our reading, the code reports a failure while the robot is still moving.
Finding 4 on GitHub →We read open-source robot MCP servers, the bridges an AI uses to move a robot. Some handle a stop while a move runs. Some only after the move ends. Some offer no stop tool at all.
Result on GitHub →Run it yourself
The stop test is open code: Python, numpy and MuJoCo, on Unitree's published files at a pinned commit. The first script ran in 3.3 seconds in our sandbox.
$ git clone https://github.com/botinfo-ai/humanoid-stop-sim && cd humanoid-stop-sim
$ pip install numpy==2.0.2 mujoco==3.3.7
$ mkdir -p in/unitreerobotics out
$ git clone https://github.com/unitreerobotics/unitree_rl_gym in/unitreerobotics/unitree_rl_gym
$ git -C in/unitreerobotics/unitree_rl_gym checkout 3e70454dae9562febade2949c9ebc57440365dcb
$ python3 sim/stop_walk.py in out
Published tests
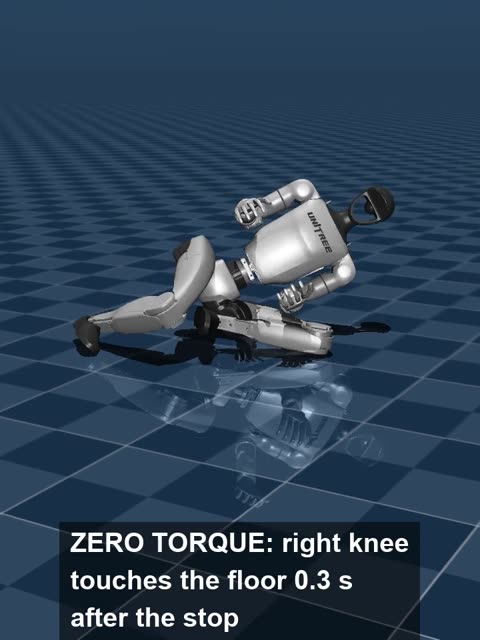 Simulation
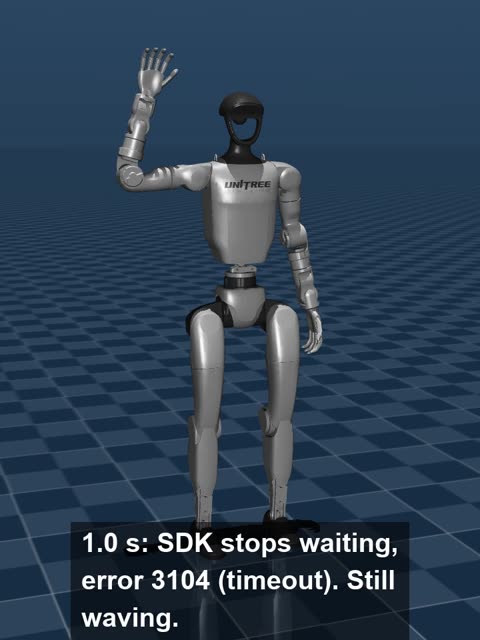 Simulation video
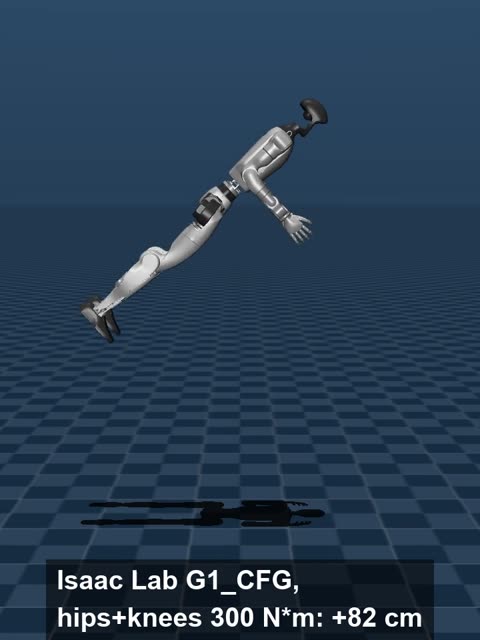 Simulation video
The robots in our videos are published simulation models posed or driven by our scripts, not real robots.
Seen in person
We filmed this DEEP Robotics Lynx M20 being driven on a lawn at Bay Area Robotics on 10 September 2026. We have not tested it. Our tests so far run in simulation or read public code.
How we know
Simulation tests run in a sealed sandbox on published robot models pinned to an exact version, so anyone can load the same file.
Before a result goes out, an AI agent that did not write it reopens every cited source. A failed check publishes nothing.
Every claim carries its source and the date we read it. When we are wrong, we fix it and date the fix.
What we tested on the G1 in simulation, and what Unitree's own code, public records and rules show, each finding with its source and date.
See the G1 evidence →What each robot is and which US rules apply, with the date each fact was checked.
For organisations
We sell a full evidence file on it, every claim graded and dated. We start with a written quote by email.
New tests go to GitHub first. Found an error? Write to [email protected]. We fix it and date the fix.


